Areas of application
Communication for inspection platforms working around energy, production and transport assets, along corridors, offshore and underground.
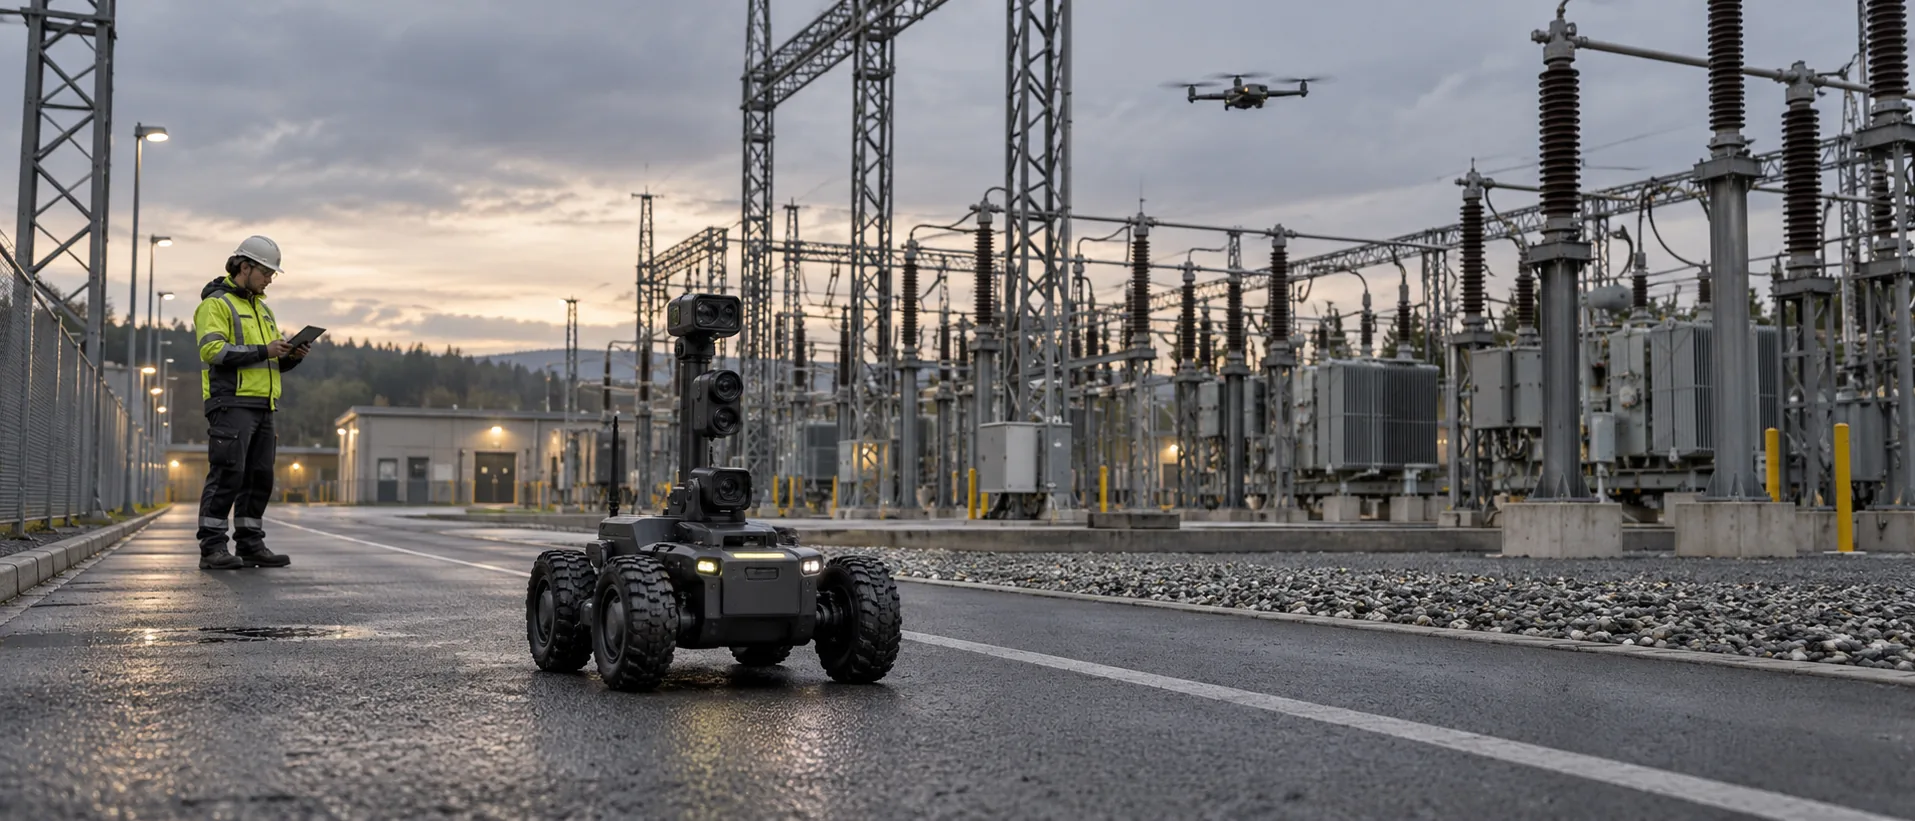
Energy asset inspection
Connect drones and ground robots inspecting substations and other power facilities. Carry camera imagery and command data between the inspection platform and its operator, with the radio setup planned around the site.
Pipeline and power line corridors
Connect a drone inspecting a pipeline or power line far along its route. Carry video and command data over long distances, with static relay nodes along the corridor where the terrain blocks a direct path.
Industrial site inspection
Link two ground robots inspecting pipework, equipment and access corridors within a processing facility. The robot nearer the edge relays for the one deeper inside, so camera views reach the operator past the site’s metal structures.
Transport asset inspection
Connect a drone inspecting the underside of a railway bridge or another hard-to-reach structure. A second drone above the deck relays its link, so camera views reach the operator even where the structure blocks a direct path.
Offshore wind farms
Connect an inspection drone and an uncrewed surface vessel at offshore turbines with the operator on a service ship. Carry video and command data across open water between the turbines and the ship.
Underground and mining
Connect a ground robot working in a tunnel or mine with an operator at the entrance. Relay nodes placed along the passage as the robot advances carry commands in and video back where a direct link cannot reach.
These are illustrative, simplified concepts of operations. A real setup depends on your platforms, environment and mission.
Why Hive fits industrial applications
Inquiries
Build around your site requirements
Share the inspection task, platform design and site constraints. We’ll discuss a communication configuration and the housing, antenna and power requirements for your integration.
- Email sales@hive-robotics.com