Software
HSWARM
HSWARM is the command layer for swarming and teaming. It connects individual robotic systems into coordinated teams over the same mesh link, so they share information and coordinate their actions. Integrate it into your own application.
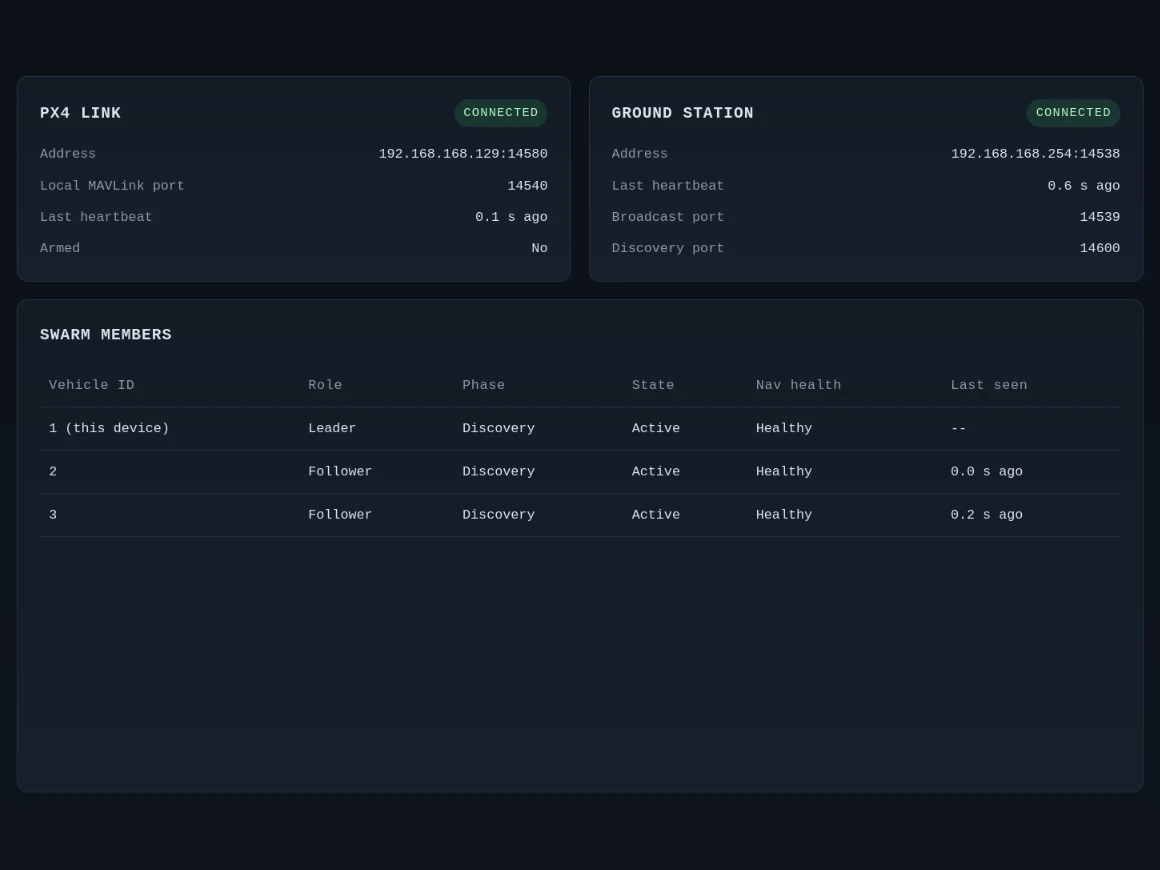
For illustrative purposes only.
Autonomy
HSWARM Features
HSWARM
Enable robotic systems to share information and coordinate their actions. Integrate swarming and teaming capabilities into your application.
Time-of-flight ranging
Estimate distances between nodes by measuring signal travel time. Use these measurements to support relative positioning.
GNSS-denied navigation
Support navigation when satellite positioning is unavailable. Use alternative positioning inputs to support continued operation.
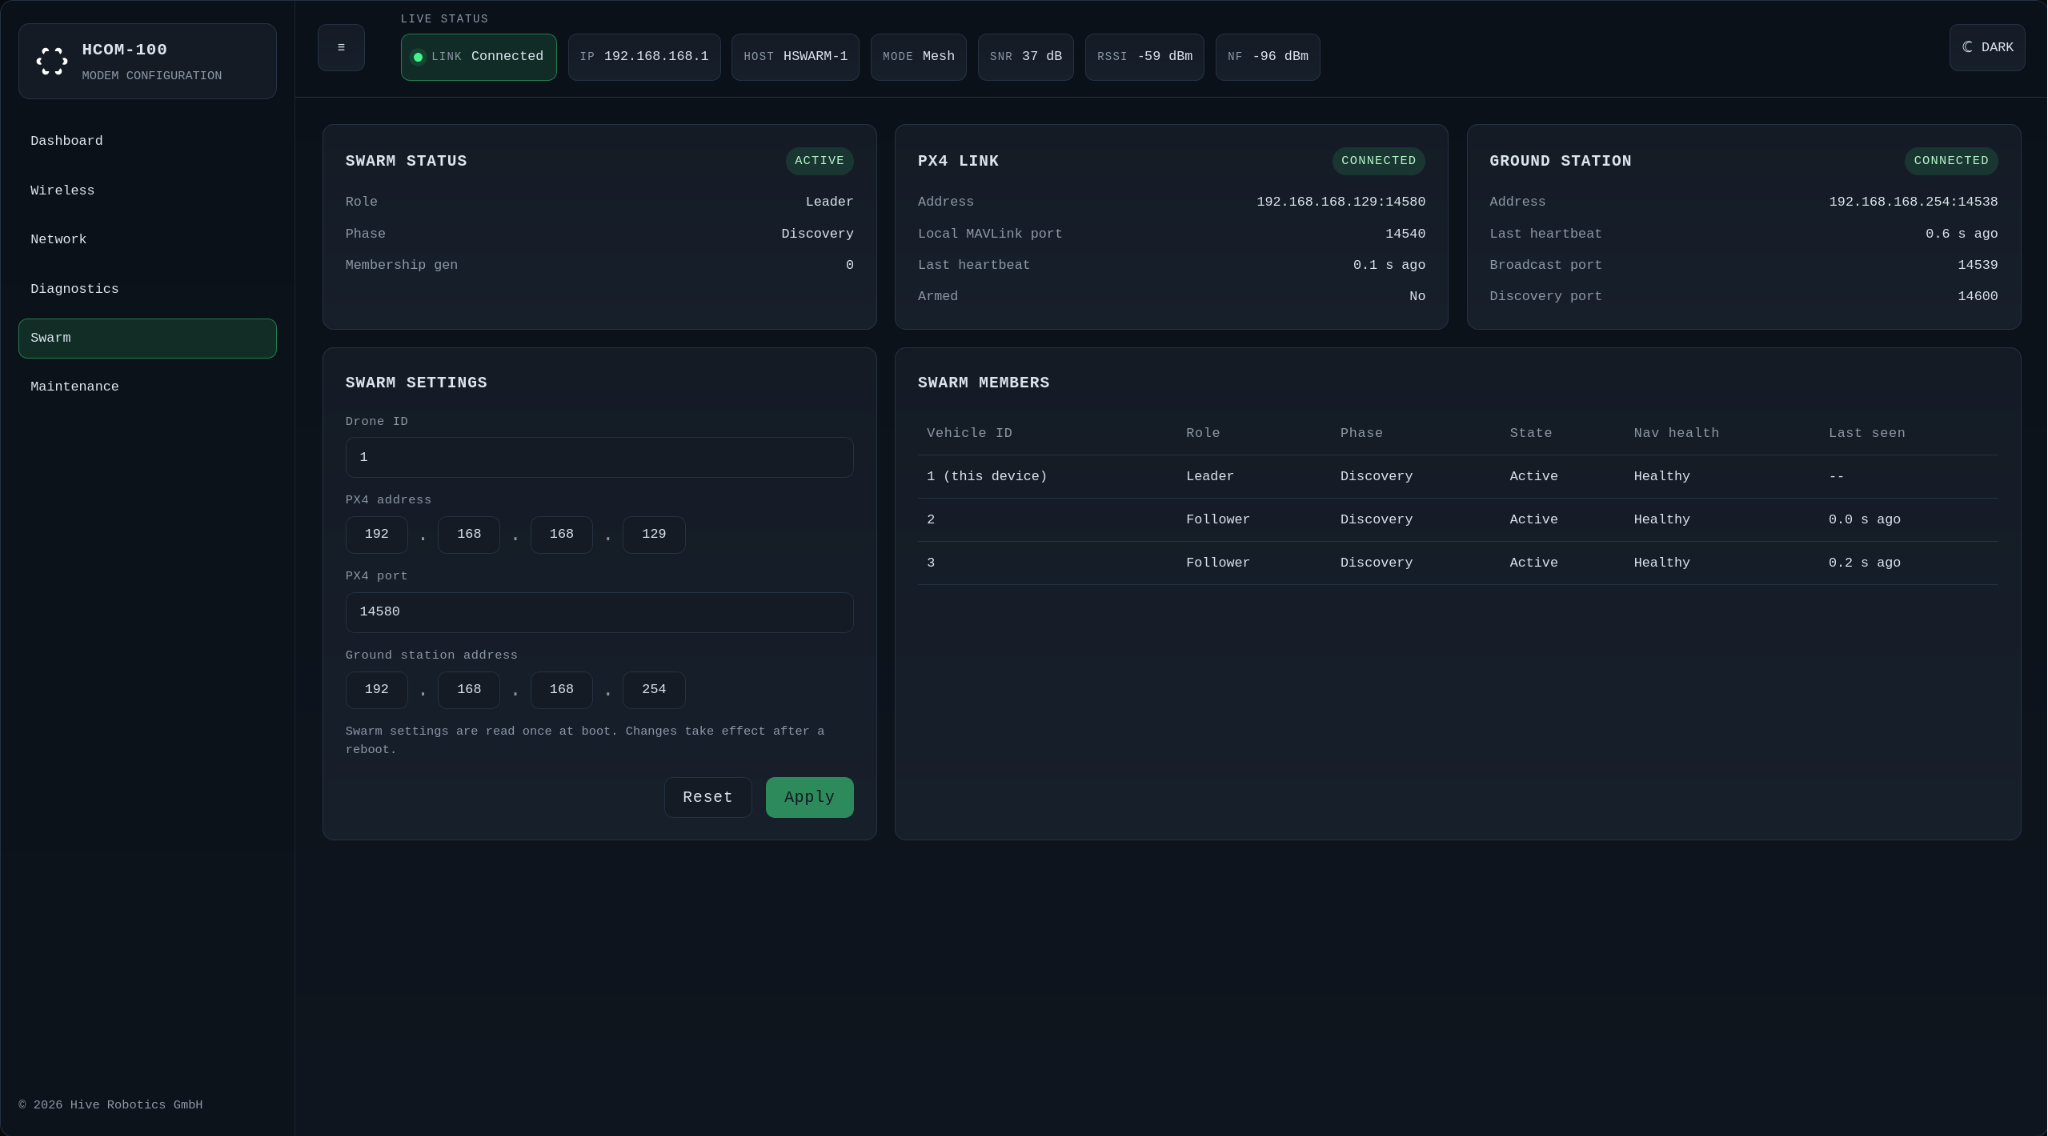
For illustrative purposes only. HSWARM is in development, and its full capability depends on the complete system it is integrated into.
Inquiries
Contact
Interested? Tell us your requirements, concept of operations and link type. We will propose a solution.
- Email sales@hive-robotics.com